AgiBot puts perception and balance in one model
AGIBOT / press releasePress kit
AgiBot, the Shanghai robotics company also known as 智元机器人, announced AGILE 2.0 on 11 September 2026. The company describes it as a single model joining visual perception to whole-body motor control, so that a robot reads its surroundings and adjusts its footing in the same loop rather than passing a map from one system to another.
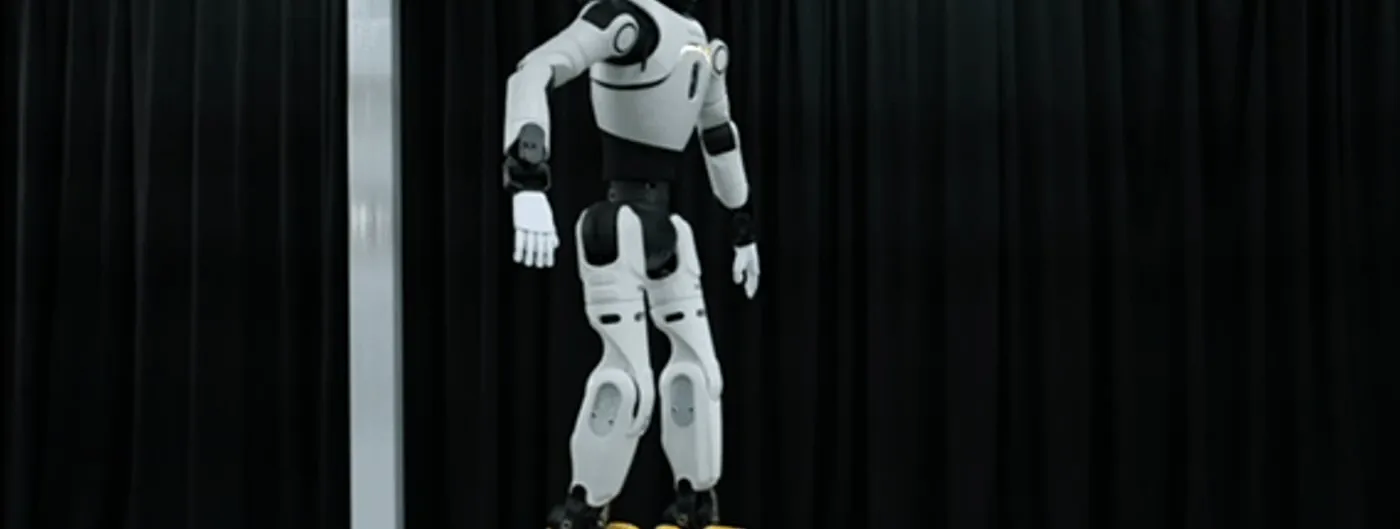
The release came with a short film shot on the Lingxi X2, AgiBot’s bipedal humanoid. In it the robot walks on top of a large ball while keeping its balance, jumps through suspended hoops, and turns a long rope in time with other units. AgiBot claims the ball-walking as a first for a bipedal robot; that claim rests on the company’s own account.
Demonstration films are not deployments, and a controlled studio is not a street. What the release does mark is a design choice being made in public: several Chinese humanoid makers are now collapsing the perception stack and the locomotion controller into one trained model, instead of tuning a balance controller and feeding it a processed world.
AgiBot published a second model, GE-Act 2.0, two days earlier, covering manipulation rather than locomotion.