A robot hand with two air lines out-turns the human wrist
Researchers at the Nanjing University of Information Science and Technology, the Shenzhen Institutes of Advanced Technology and Tongji University published a manipulator on 13 August 2026 in Advanced Science that reaches most of the hand’s core motions without fingers. BioflexBot is a coiled spring inside a constraining shell, driven by two pneumatic inputs. Pressure and the shell together decide whether the spring pinches, rotates, hooks or grasps.
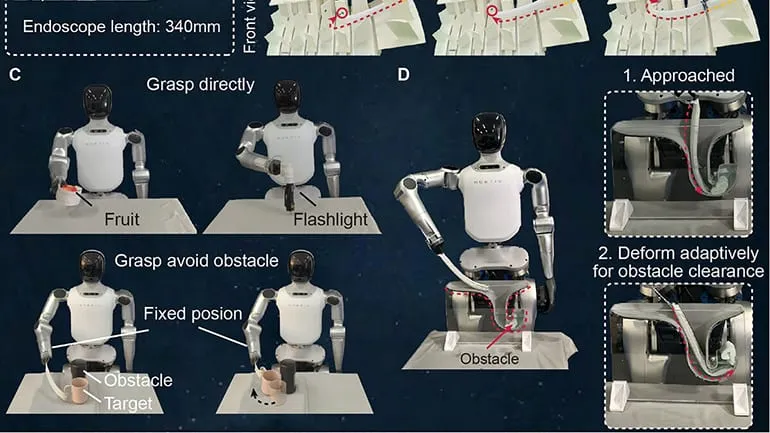
The measured gains are in range rather than delicacy. It extends and contracts 3.5 times as far as a human hand, turns a bottle cap nearly four times further in one motion, and handles objects up to nearly 13 times larger than comparable systems. The demonstrations run from threading an acupuncture needle and pipetting liquid to inspecting aeroengine blades through a 340 mm endoscope path and, mounted on a humanoid torso, reaching around an obstacle to a target a rigid arm could not.
Dexterous hands are the expensive, fragile part of every humanoid, and most designs answer the problem by adding actuators. This one removes them. Whether two inputs survive contact with the variety of a real task is what the paper does not yet show.