A humanoid crosses monkey bars using only onboard lidar
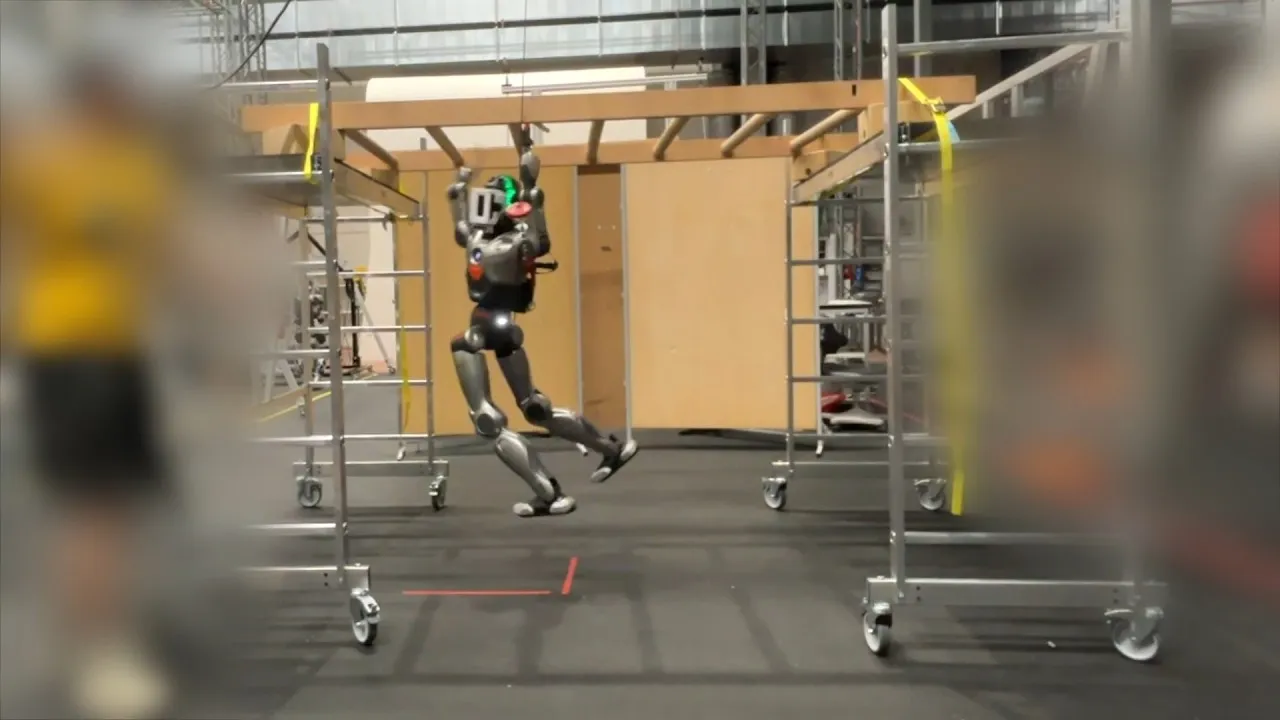
▶ Robotic Systems Lab: Legged Robotics at ETH Zürich — YouTubeVideo frame
Researchers at ETH Zurich’s Robotic Systems Lab and ETH AI Center posted a preprint on 30 August 2026 describing a humanoid robot that jumps onto an overhead ladder, swings hand over hand along it, and drops back to the floor. The full sequence completed in 14 of 15 hardware trials across three bar spacings, with brachiation speeds reaching 0.5 m/s.
What distinguishes the result is the input. The control policy reads a head-mounted solid-state lidar directly, rather than being handed the position of each bar. Thin overhead rungs return very few points, so the system has to act on a sparse and noisy picture of where the structure is. An attention-based encoder with recurrent memory pulls the task-relevant geometry out of that scan.
Training used a phase-scheduled teacher-student pipeline, with separate privileged experts for jumping up, swinging, and jumping down, distilled into one policy that runs on the robot’s own sensing. The same perception stack drives a second policy for ducking under overhead obstacles with cross-sections of 2 cm. The robot wears passive hooks as end-effectors rather than gripping hands.
The work is a preprint and has not been peer reviewed. IEEE Spectrum featured the video in its 11 September 2026 roundup.