Unitree releases UnifoLM-WLA-1.0, one model for 64 robot tasks
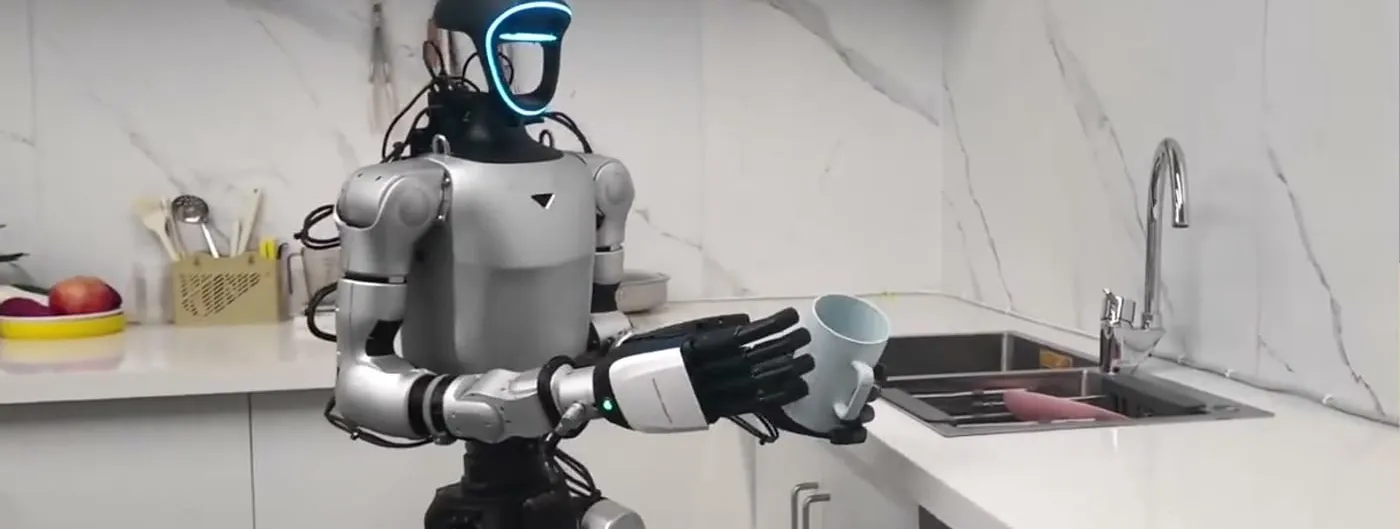
Unitree Robotics published UnifoLM-WLA-1.0 on 10 September 2026, a 6-billion-parameter foundation model for humanoid manipulation. The name stands for world-language-action: the model carries an internal model of how the world responds to what the robot does, rather than mapping instructions straight onto motor commands.
It was trained on roughly 2,500 hours of real-robot data, together with about five million embodied-reasoning samples, the Unitree open datasets and the BitRobot-HIW-500 set. A single checkpoint covers 64 tasks — 54 tabletop manipulation and 10 whole-body — and drives both two-finger grippers and several five-finger dexterous hands. Unitree’s own framing is one model driving all of it, with whole-body coordination.
That is the claim worth holding onto. Robot manipulation policies have historically been narrow: one model per task, often one per gripper, retrained when the hardware changes. A single set of weights that transfers across 64 tasks and several end effectors is the argument that manipulation is becoming a general capability rather than a catalogue of demonstrations.
Code, model weights and datasets are published on GitHub and Hugging Face. The release is separate from UnifoLM-X2-1.0, the control model behind Unitree’s autonomous sparring demonstration three days earlier.